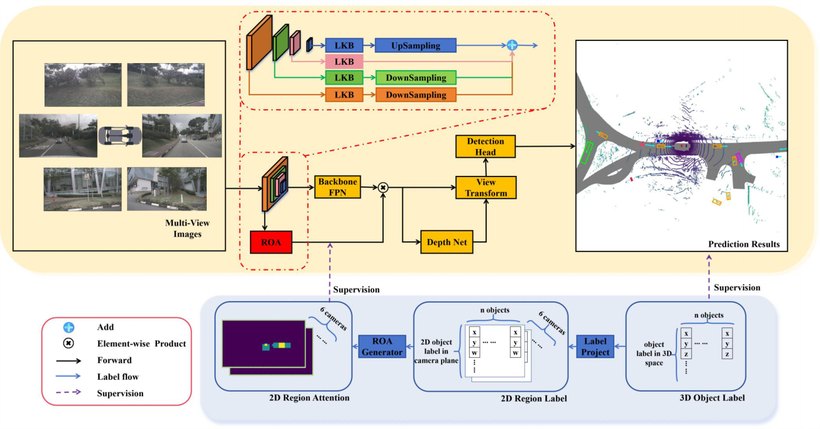
ROA-BEV: 2D Region-Oriented Attention for BEV-based 3D Object Detection
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025
陈基伟
Ph.D. Candidate
School of Science and Engineering, The Chinese University of Hong Kong, Shenzhen
理工学院 · 计算机与信息工程
Compressed Sensing Image Reconstruction · 3D Object Detection · Autonomous Driving VLA Models
Jiwei Chen is a Ph.D. candidate in Computer and Information Engineering at the School of Science and Engineering, The Chinese University of Hong Kong, Shenzhen, advised by Prof. Rui Huang. He received his M.Eng. in Control Science and Engineering from Nanjing University of Information Science and Technology (NUIST), advised by Prof. Yubao Sun, and his B.Eng. in Automation from NUIST.
His research interests include compressed sensing image reconstruction, 3D object detection for autonomous driving, and vision-language-action (VLA) models for driving. His work has been published in Pattern Recognition, IEEE TIP, IEEE TMM, ECCV, and IROS, and he holds several authorized and published patents. His current work focuses on open-world 3D object detection for open roads, and on detecting abnormal-condition objects and understanding scene semantics in driving scenarios. He is open to academic collaborations and research discussions.
Deep-network-based CS image reconstruction, including generative adversarial networks, dual-path attention, memory-augmented cascading, and non-local regularization methods.
BEV-based 3D object detection, and VLM-based open-world 3D detection for 3D localization and open-vocabulary semantic description of known and unknown objects.
Architecture, training, and closed-loop validation of vision-language-action models for driving, covering data annotation loops, training acceleration, simulation-based validation, and reinforcement learning.
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025
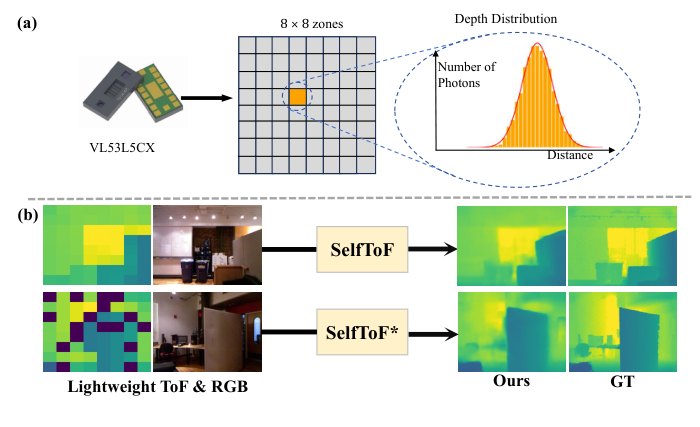
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025
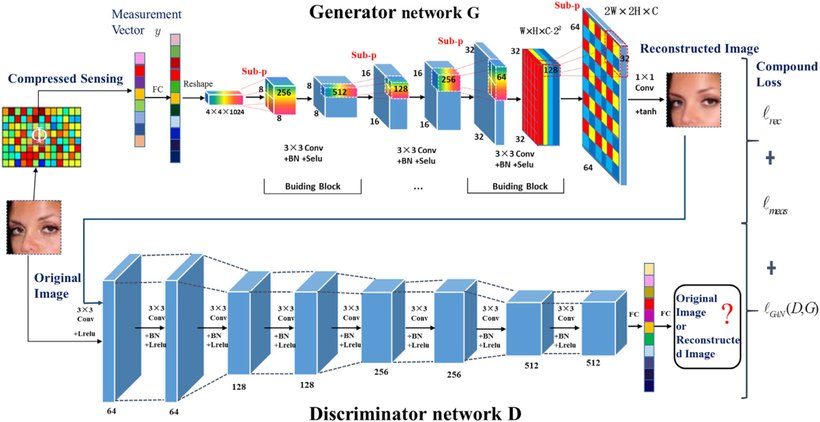
Pattern Recognition (PR), 2020, 98: 107051
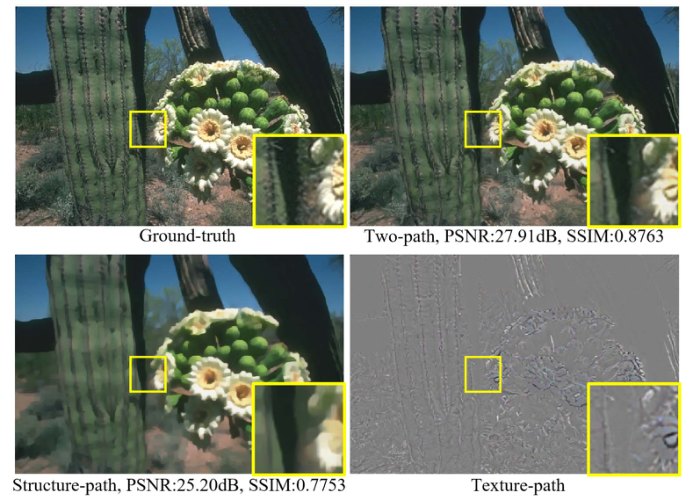
IEEE Transactions on Image Processing (TIP), 2020
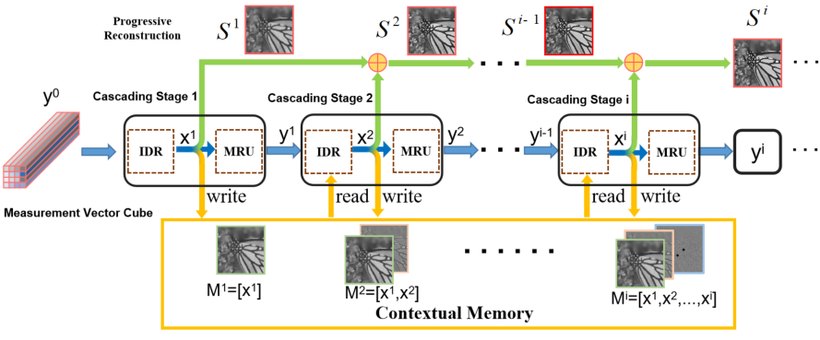
European Conference on Computer Vision (ECCV), 2020
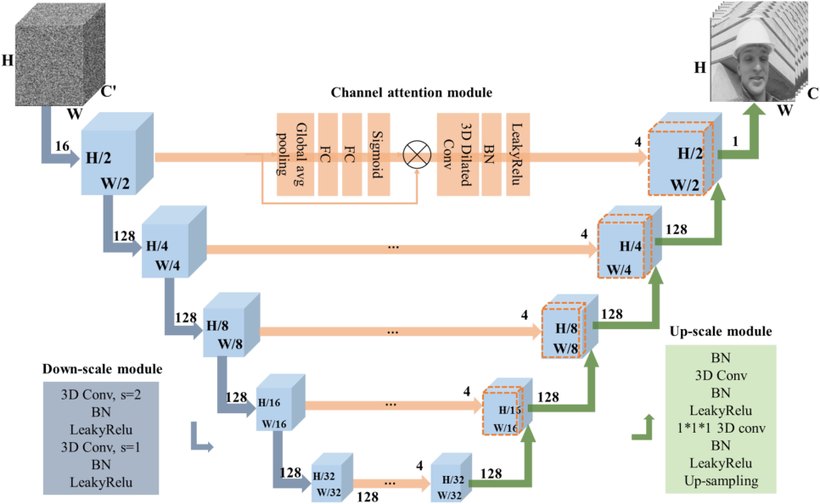
IEEE Transactions on Multimedia (TMM), 2020
Under review at IEEE Transactions on Human-Machine Systems
An industrial collaboration with Freetech. As the main technical lead, responsible for architecture design and training of the algorithms, covering data annotation closed loops, training acceleration, simulation-based validation, and reinforcement learning training, and driving deployment with the company while distilling problems for future publications.
Studied anomaly recognition for road environment changes, and implemented the algorithms and visualization, meeting the project's target metrics.